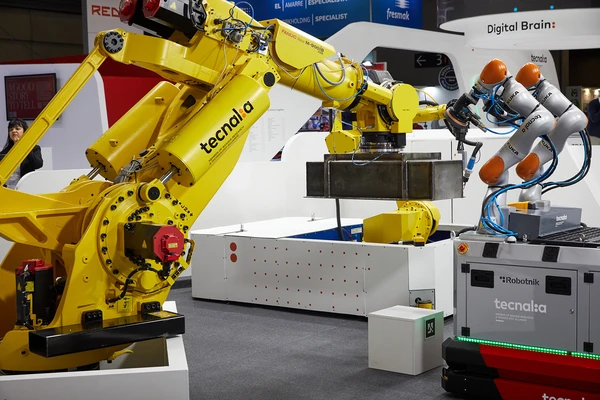
The service provides real-time, coordinated trajectory planning for dual-arm robots, integrating live data from external perception systems to adapt to dynamic environmental constraints. The service accounts for both external obstacles and the robot’s mechanical and dynamic limitations, ensuring safe, efficient, and collision-free movement. Ideal for collaborative and complex automation tasks. This service enhances automation in applications such as collaborative manufacturing, assembly, and logistics, where adaptability, safety, and precision are critical.
Manufacturers, assemblers, and logistics operators that require coordinated dual-arm robotic systems to perform complex manipulation, assembly, or handling tasks in dynamic environments.